Controls / simulation / 2026 — ongoing
CasMuMPC
Model predictive control with CasADi and MuJoCo.
Personal project
Overview
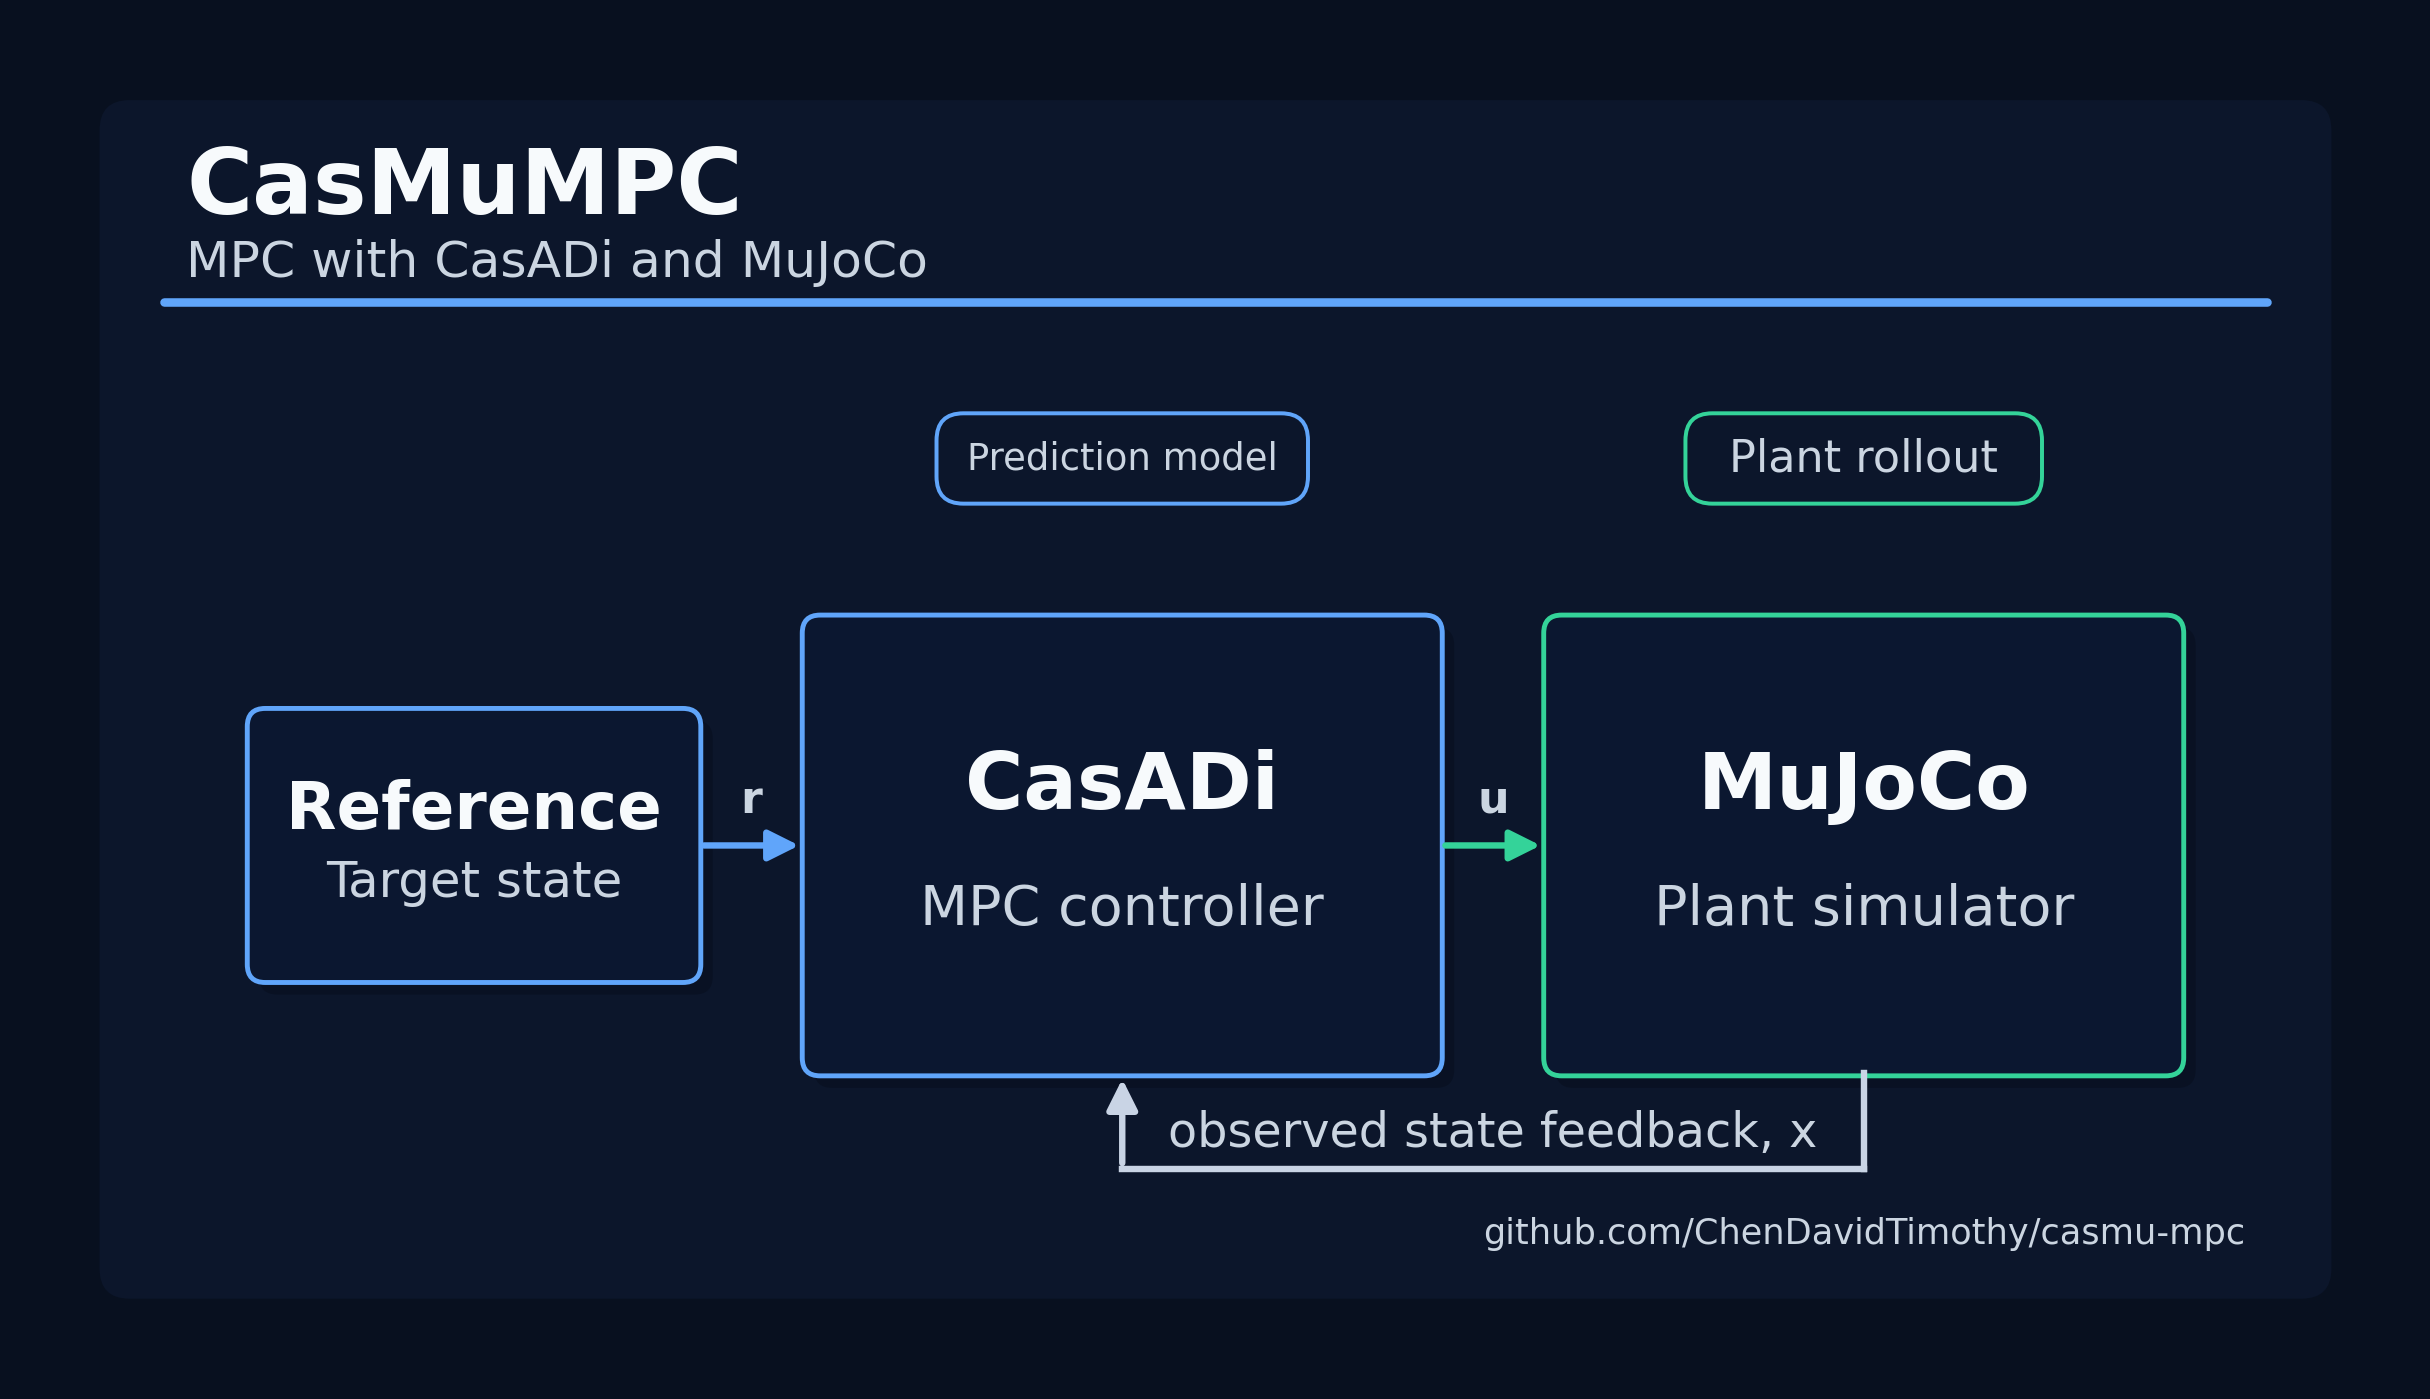
Small, readable examples of closed-loop model predictive control. CasADi defines the controller model and optimization problem; MuJoCo runs the simulated plant.
What I worked on
- Keep the prediction model separate from the simulated system.
- Make state and coordinate mappings between controller and plant explicit.
- Include examples for pendulum tracking, cart-pole stabilization, acrobot swing-up, and a double inverted pendulum.